01
Application context
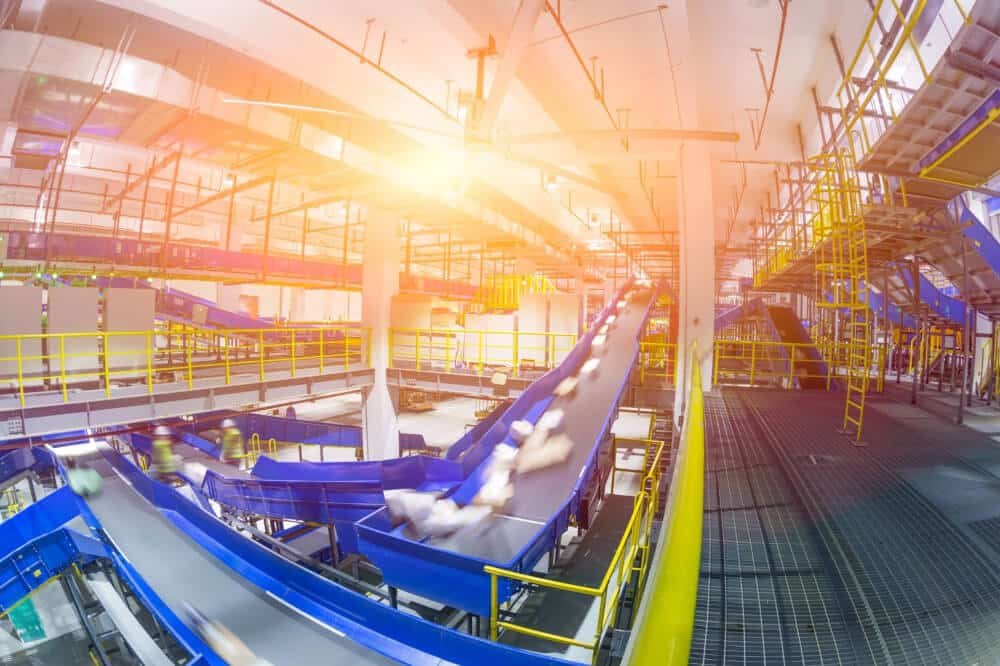
Pharmacists and technicians were manually carrying totes between various order filling stations and the area for verifying and packing.
Operators are positioned at several workstations throughout the system where prescription filling robots are located.
02
Design considerations
The operator fills a tote with the required prescription and places it on the conveyor level that sends it to additional locations for order filling. Once the order is complete, the tote will be placed back on the system which then sends the order to a location where in can be verified and packed.
Finally, the empty tote is returned to the lower level that takes the empty totes to the various workstations for the next new orders.